Culvert Inspection
Robot perception and locomotion for infrastructure inspection.
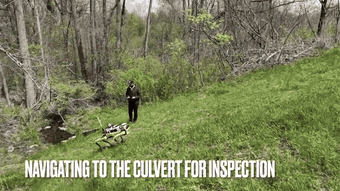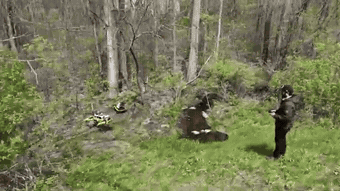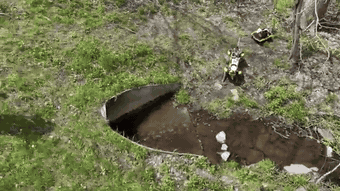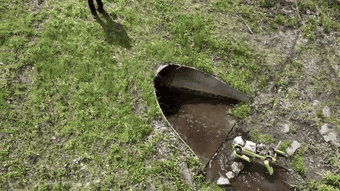
Culvert inspection is the second major application theme currently highlighted in the lab: a good example of autonomy and perception designed for infrastructure settings rather than clean indoor demos.
- Low-light perception - NightHawk [ISER25], Lightning [arXiv26]
- Legged Locomotion in Unstructured Terrain - CART [arXiv26], Task-Conditioned Uncertainty Costmaps [arXiv26]
- LLM-assisted Inspection - VISION [arXiv25]
Funding