@article{TBME26,author={Dalland, Kristian and Chowdhury, Souma and Dantu, Karthik and Esfahani, Ehsan T.},title={Adaptive Hiking-Time Prediction Through State-Dependent Energy Regulation},journal={IEEE Transactions on Biomedical Engineering},year={2026},pages={1--10},publisher={Institute of Electrical and Electronics Engineers (IEEE)},note={Early Access},doi={10.1109/tbme.2026.3720250},url={https://ieeexplore.ieee.org/document/11643221/},}
IJRR
AnyNav: Visual Neuro-Symbolic Friction Learning for Off-road Navigation
Taimeng Fu, Zitong Zhan, Zhipeng Zhao, Shaoshu Su, Xiao Lin, Ehsan Tarkesh Esfahani, Karthik Dantu, Souma Chowdhury, and Chen Wang
The International Journal of Robotics Research, 2026
@article{IJRR26,author={Fu, Taimeng and Zhan, Zitong and Zhao, Zhipeng and Su, Shaoshu and Lin, Xiao and Esfahani, Ehsan Tarkesh and Dantu, Karthik and Chowdhury, Souma and Wang, Chen},title={AnyNav: Visual Neuro-Symbolic Friction Learning for Off-road Navigation},journal={The International Journal of Robotics Research},year={2026},url={https://arxiv.org/abs/2501.12654},}
RA-L
CLEAR: A Semantic–Geometric Terrain Abstraction for Large-Scale Unstructured Environments
@article{RALJ26,author={Meshram, Pranay and Adhivarahan, Charuvahan and Esfahani, Ehsan Tarkesh and Chowdhury, Souma and Wang, Chen and Dantu, Karthik},title={CLEAR: A Semantic–Geometric Terrain Abstraction for Large-Scale Unstructured Environments},journal={IEEE Robotics and Automation Letters},year={2026},volume={11},number={10},pages={11394--11401},publisher={Institute of Electrical and Electronics Engineers (IEEE)},doi={10.1109/lra.2026.3726338},url={https://ieeexplore.ieee.org/document/11662374/},note={Accepted September 2026},}
TAES
Comparative Analysis of Feature Tracking Challenges in Unstructured Space Environments
@article{tracking,author={Chase, Timothy and Balotin, Andrew and Dantu, Karthik},title={Comparative Analysis of Feature Tracking Challenges in Unstructured Space Environments},journal={IEEE Transactions on Aerospace and Electronic Systems},year={2026},volume={62},pages={6166--6179},publisher={Institute of Electrical and Electronics Engineers (IEEE)},doi={10.1109/taes.2026.3667132},url={https://ieeexplore.ieee.org/document/11408193/},}
Commun. Eng.
Determining the percentage of recycled plastic content in a plastic product
Yaoli Zhao, Charuvahan Adhivarahan, Chandra Lekha Jyothula, Karthik Dantu, Thomas Thundat, and Amit Goyal
@article{recycled,author={Zhao, Yaoli and Adhivarahan, Charuvahan and Jyothula, Chandra Lekha and Dantu, Karthik and Thundat, Thomas and Goyal, Amit},title={Determining the percentage of recycled plastic content in a plastic product},journal={Communications Engineering},year={2026},volume={5},number={1},article_number={51},publisher={Springer Science and Business Media LLC},doi={10.1038/s44172-026-00639-y},url={https://www.nature.com/articles/s44172-026-00639-y},}
JCISE
Efficient Planning for Scalable and Load-Balanced Area Coverage by Multiple Unmanned Aerial Vehicles
Prajit KrisshnaKumar, Jhoel Witter, Leighton Collins, Jagadeswara P. K. V. Pothuri, Payam Ghassemi, Ehsan T. Esfahani, Karthik Dantu, and Souma Chowdhury
Journal of Computing and Information Science in Engineering, 2026
@article{JCIS26,author={KrisshnaKumar, Prajit and Witter, Jhoel and Collins, Leighton and Pothuri, Jagadeswara P. K. V. and Ghassemi, Payam and Esfahani, Ehsan T. and Dantu, Karthik and Chowdhury, Souma},title={Efficient Planning for Scalable and Load-Balanced Area Coverage by Multiple Unmanned Aerial Vehicles},journal={Journal of Computing and Information Science in Engineering},year={2026},volume={26},number={9},article_number={091002},publisher={ASME International},doi={10.1115/1.4071466},url={https://asmedigitalcollection.asme.org/computingengineering/article/26/9/091002/1232074/Efficient-Planning-for-Scalable-and-Load-Balanced},}
JPCB
Explainable Deep Learning and Targeted Spectral Augmentation for Mid-Infrared Classification of Additive-Containing Polymers
Nicholas Stavinski, Vaishali Maheshkar, Charutha Dassanayake, Fransuas P. González Ortiz, Gleniarys N. Rivera-Torres, Karthik Dantu, and Luis Velarde
@article{JPCB26,author={Stavinski, Nicholas and Maheshkar, Vaishali and Dassanayake, Charutha and González Ortiz, Fransuas P. and Rivera-Torres, Gleniarys N. and Dantu, Karthik and Velarde, Luis},title={Explainable Deep Learning and Targeted Spectral Augmentation for Mid-Infrared Classification of Additive-Containing Polymers},journal={The Journal of Physical Chemistry B},year={2026},volume={130},number={31},pages={8092--8102},publisher={American Chemical Society (ACS)},doi={10.1021/acs.jpcb.6c02143},url={https://pubs.acs.org/jpcbfk/article/130/31/8092/5233880/Explainable-Deep-Learning-and-Targeted-Spectral},}
Front. Robot. AI
Designing socially assistive robots for clinical practice: insights from an asynchronous remote community of speech-language pathologists
Denielle Oliva, Abbie Olszewski, Shekoufeh Sadeghi, Karthik Dantu, and David Feil-Seifer
@article{FRRA25,author={Oliva, Denielle and Olszewski, Abbie and Sadeghi, Shekoufeh and Dantu, Karthik and Feil-Seifer, David},title={Designing socially assistive robots for clinical practice: insights from an asynchronous remote community of speech-language pathologists},journal={Frontiers in Robotics and AI},year={2025},volume={12},article_number={1646880},publisher={Frontiers Media SA},doi={10.3389/frobt.2025.1646880},url={https://www.frontiersin.org/articles/10.3389/frobt.2025.1646880/full},}
TECS
A Comprehensive Study of Systems Challenges in Visual Simultaneous Localization and Mapping Systems
@article{slamstudy,author={Semenova, Sofiya and Ko, Steven and Liu, Yu David and Ziarek, Lukasz and Dantu, Karthik},title={A Comprehensive Study of Systems Challenges in Visual Simultaneous Localization and Mapping Systems},journal={ACM Transactions on Embedded Computing Systems},year={2024},volume={24},number={1},article_number={2},pages={1--31},publisher={Association for Computing Machinery (ACM)},doi={10.1145/3677317},url={https://dl.acm.org/doi/10.1145/3677317},}
T-RO
Design of an Adaptive Lightweight LiDAR to Decouple Robot–Camera Geometry
Yuyang Chen, Dingkang Wang, Lenworth Thomas, Karthik Dantu, and Sanjeev J. Koppal
@article{TROJ24,author={Chen, Yuyang and Wang, Dingkang and Thomas, Lenworth and Dantu, Karthik and Koppal, Sanjeev J.},title={Design of an Adaptive Lightweight LiDAR to Decouple Robot–Camera Geometry},journal={IEEE Transactions on Robotics},year={2024},volume={40},pages={2254--2271},publisher={Institute of Electrical and Electronics Engineers (IEEE)},doi={10.1109/tro.2024.3371885},url={https://ieeexplore.ieee.org/document/10453967/},}
ES: Adv.
Mid-infrared spectroscopy and machine learning for postconsumer plastics recycling
Nicholas Stavinski, Vaishali Maheshkar, Sinai Thomas, Karthik Dantu, and Luis Velarde
@article{spectra,author={Stavinski, Nicholas and Maheshkar, Vaishali and Thomas, Sinai and Dantu, Karthik and Velarde, Luis},title={Mid-infrared spectroscopy and machine learning for postconsumer plastics recycling},journal={Environmental Science: Advances},year={2023},volume={2},number={8},pages={1099--1109},publisher={Royal Society of Chemistry (RSC)},doi={10.1039/d3va00111c},url={https://pubs.rsc.org/va/article/2/8/1099-1109/835854},}
TECS
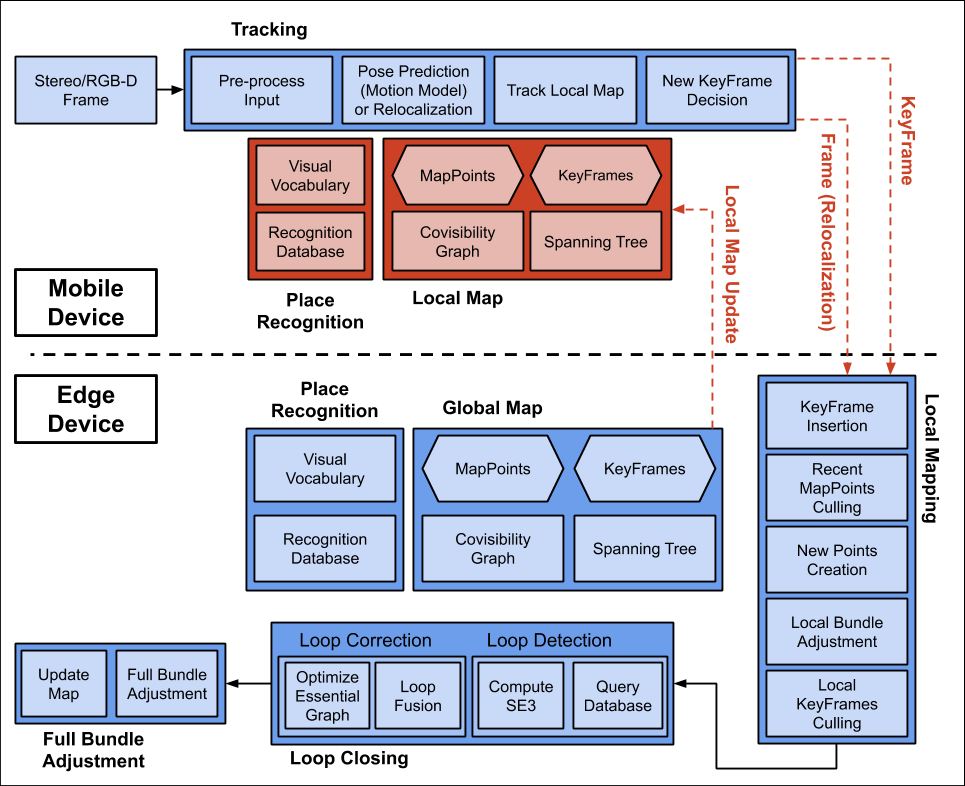
Edge-SLAM: Edge-Assisted Visual Simultaneous Localization and Mapping
@article{edgeslam2022,doi={10.1145/3561972},url={https://doi.org/10.1145/3561972},year={2022},month=oct,publisher={Association for Computing Machinery ({ACM})},volume={22},number={1},pages={1--31},article_number={18},author={Ali, Ali J. Ben and Kouroshli, Marziye and Semenova, Sofiya and Hashemifar, Zakieh Sadat and Ko, Steven Y. and Dantu, Karthik},title={Edge-{SLAM}: Edge-Assisted Visual Simultaneous Localization and Mapping},journal={{ACM} Transactions on Embedded Computing Systems},}
IMWUT
Reliable Digital Forensics in the Air: Exploring an RF-based Drone Identification System
@article{IMWU22,author={Li, Zhengxiong and Chen, Baicheng and Chen, Xingyu and Xu, Chenhan and Chen, Yuyang and Lin, Feng and Li, Changzhi and Dantu, Karthik and Ren, Kui and Xu, Wenyao},title={Reliable Digital Forensics in the Air: Exploring an RF-based Drone Identification System},journal={Proceedings of the ACM on Interactive, Mobile, Wearable and Ubiquitous Technologies},year={2022},volume={6},number={2},article_number={63},pages={1--25},publisher={Association for Computing Machinery (ACM)},doi={10.1145/3534598},url={https://dl.acm.org/doi/10.1145/3534598},}
J. Electrochem.
Standoff and Point Detection of Thin Polymer Layers Using Microcantilever Photothermal Spectroscopy
Yaoli Zhao, Patatri Chakraborty, Nicholas Stavinski, Luis Velarde, Vaishali Maheshkar, Karthik Dantu, Arindam Phani, Seonghwan Kim, and Thomas Thundat
@article{JECS22,author={Zhao, Yaoli and Chakraborty, Patatri and Stavinski, Nicholas and Velarde, Luis and Maheshkar, Vaishali and Dantu, Karthik and Phani, Arindam and Kim, Seonghwan and Thundat, Thomas},title={Standoff and Point Detection of Thin Polymer Layers Using Microcantilever Photothermal Spectroscopy},journal={Journal of The Electrochemical Society},year={2022},volume={169},number={3},article_number={037501},publisher={The Electrochemical Society},doi={10.1149/1945-7111/ac5657},url={https://iopscience.iop.org/article/10.1149/1945-7111/ac5657},}
CACM
Technical perspective: The power of low-power GPS receivers for nanosats
@article{CACM22,author={Dantu, Karthik},title={Technical perspective: The power of low-power GPS receivers for nanosats},journal={Communications of the ACM},year={2022},volume={65},number={11},pages={132},publisher={Association for Computing Machinery (ACM)},doi={10.1145/3559769},url={https://dl.acm.org/doi/10.1145/3559769},}
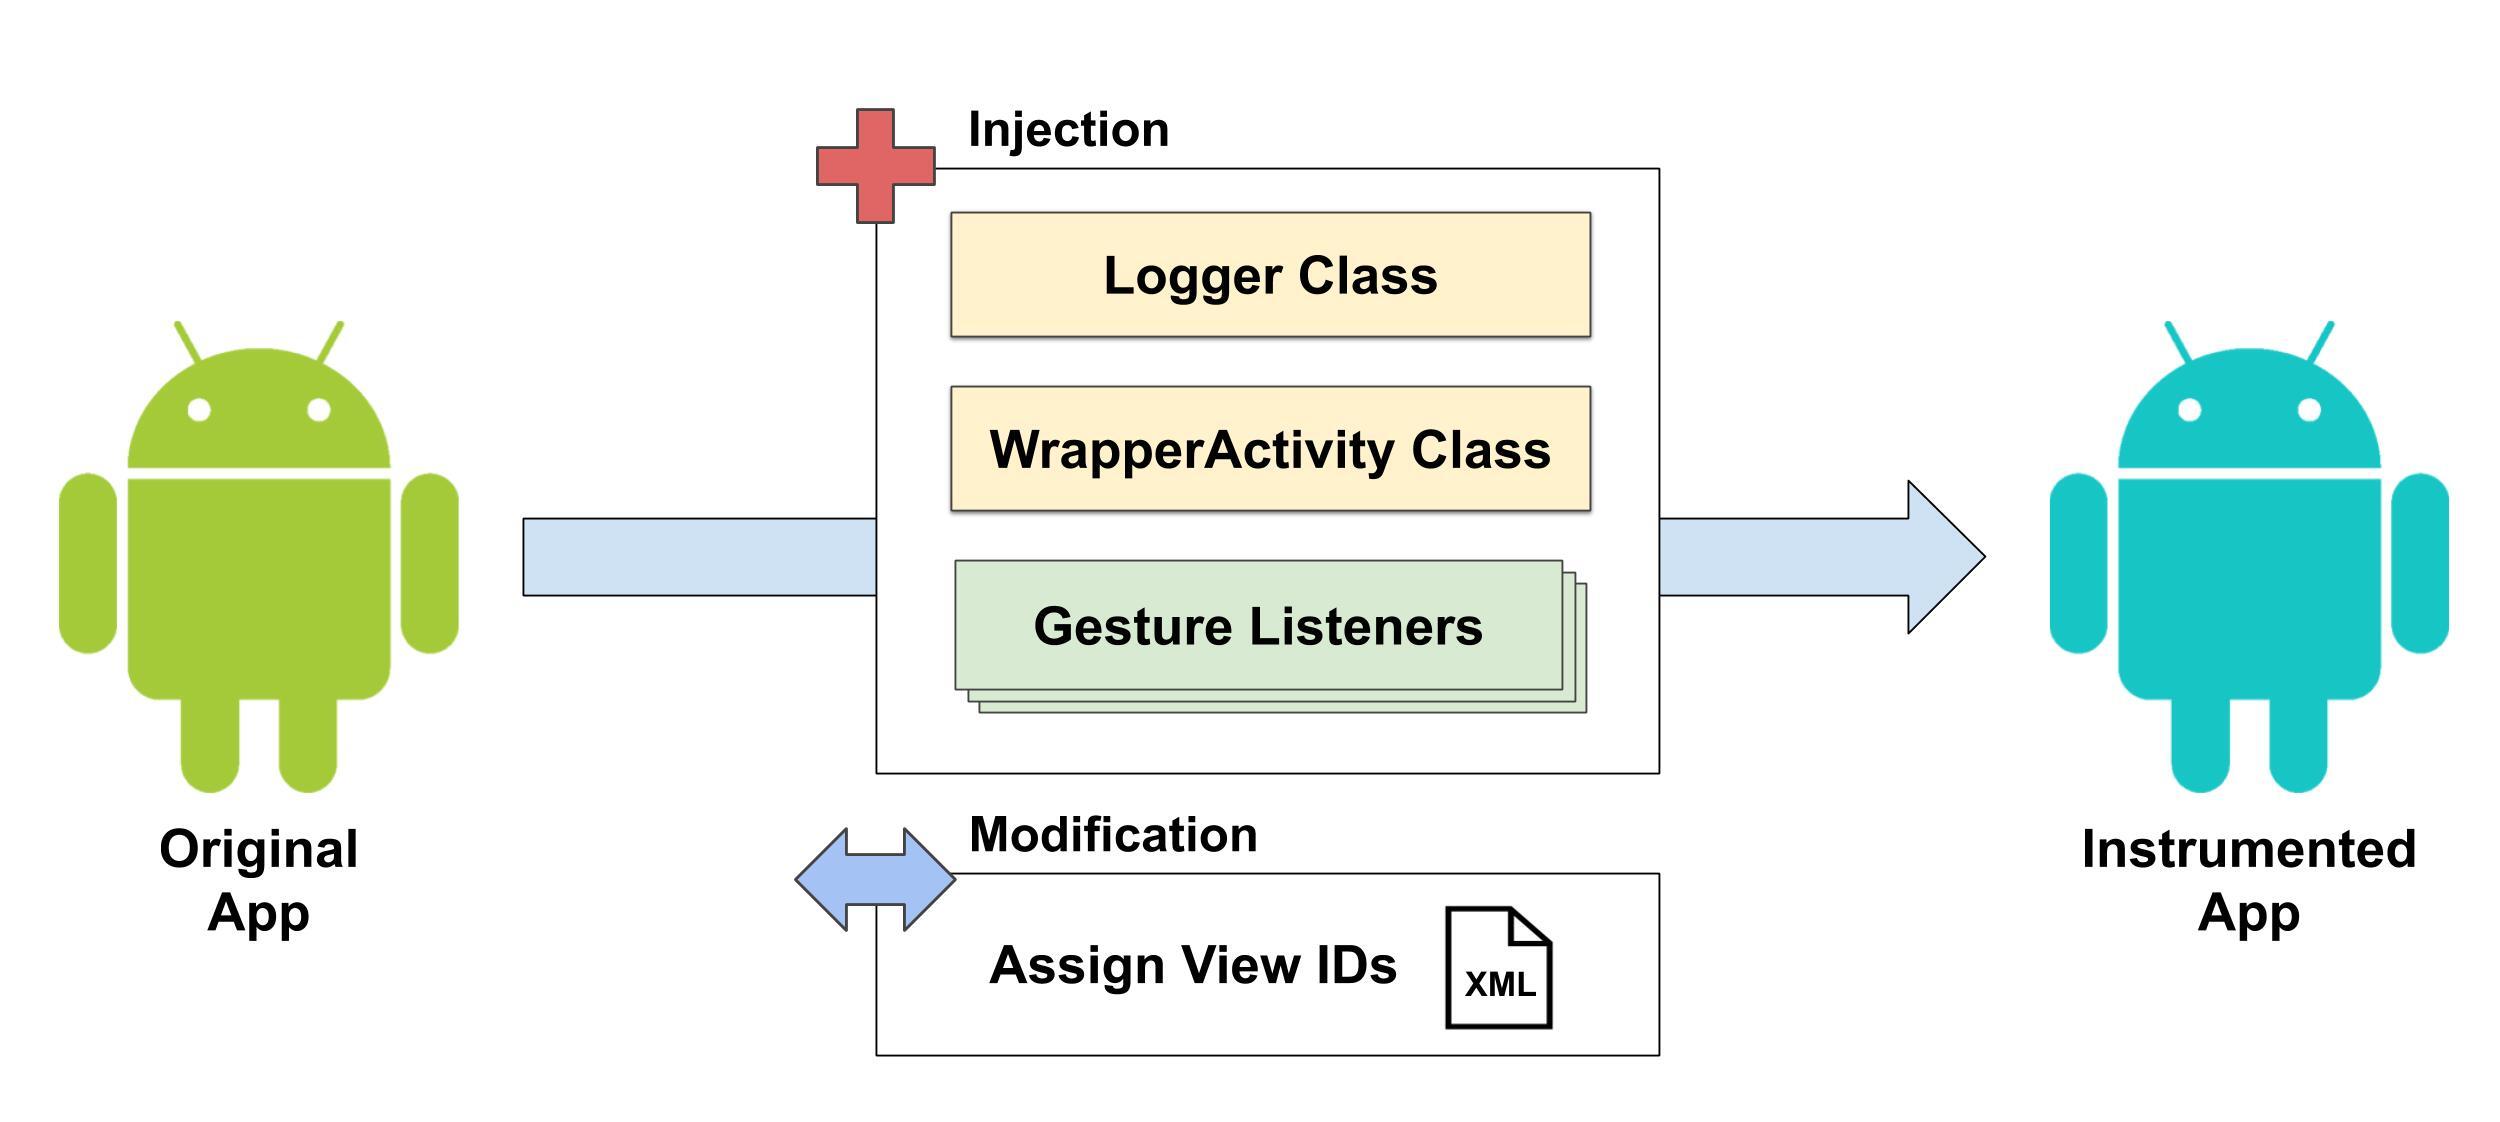
Gesto: Mapping UI Events to Gestures and Voice Commands
Chang Min Park, Taeyeon Ki, Ali J. Ben Ali, Nikhil Sunil Pawar, Karthik Dantu, Steven Y. Ko, and Lukasz Ziarek
Proceedings of the ACM on Human-Computer Interaction (PACM HCI), Jun 2019
@article{gesto,author={Park, Chang Min and Ki, Taeyeon and Ben Ali, Ali J. and Pawar, Nikhil Sunil and Dantu, Karthik and Ko, Steven Y. and Ziarek, Lukasz},title={Gesto: Mapping UI Events to Gestures and Voice Commands},year={2019},issue_date={June 2019},publisher={Association for Computing Machinery},address={New York, NY, USA},volume={3},number={EICS},url={https://doi.org/10.1145/3300964},doi={10.1145/3300964},journal={Proceedings of the ACM on Human-Computer Interaction (PACM HCI)},month=jun,articleno={5},numpages={22},keywords={voice commands, gestures, mapping UI events, record and replay},}
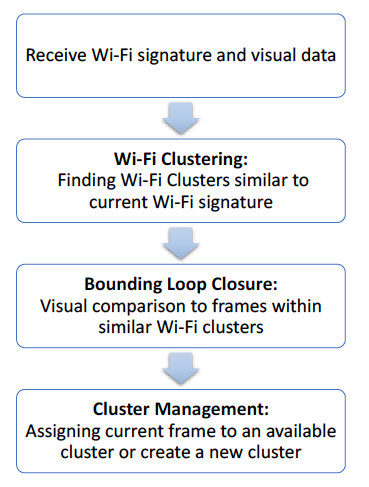
Augmenting Visual SLAM with Wi-Fi Sensing for Indoor Applications
@article{wifi,author={Hashemifar, Zakieh S. and Adhivarahan, Charuvahan and Balakrishnan, Anand and Dantu, Karthik},title={Augmenting Visual {SLAM} with Wi-Fi Sensing for Indoor Applications},journal={Autonomous Robots},volume={43},number={8},pages={2245--2260},year={2019},url={https://doi.org/10.1007/s10514-019-09874-z},doi={10.1007/s10514-019-09874-z},timestamp={Sat, 12 Oct 2019 12:50:38 +0200},biburl={https://dblp.org/rec/journals/arobots/HashemifarA0D19.bib},bibsource={dblp computer science bibliography, https://dblp.org},}
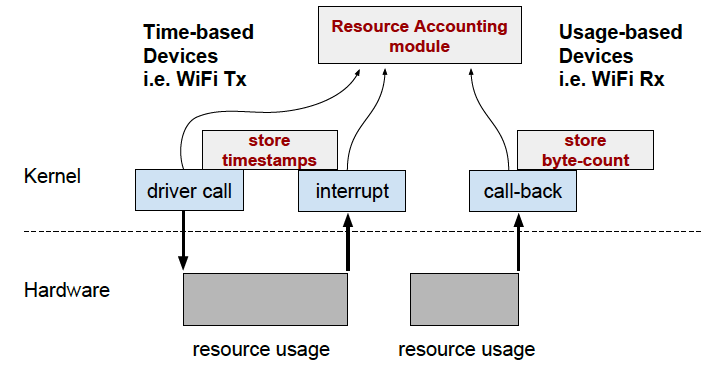
OS-based energy accounting for asynchronous resources in IoT devices
Farshad Ghanei, Pranav Tipnis, Kyle Marcus, Karthik Dantu, Steven Y Ko, and Lukasz Ziarek
@article{ghanei2019based,title={OS-based energy accounting for asynchronous resources in IoT devices},author={Ghanei, Farshad and Tipnis, Pranav and Marcus, Kyle and Dantu, Karthik and Ko, Steven Y and Ziarek, Lukasz},journal={IEEE Internet of Things Journal},volume={6},number={3},pages={5841--5852},year={2019},publisher={IEEE},url={https://ieeexplore.ieee.org/document/8674793},}
Conference Publications
IROS
SLAM Adversarial Lab: An Extensible Framework for Visual SLAM Robustness Evaluation under Adverse Conditions
@inproceedings{IROS26a,author={Hefny, Mohamed and Dantu, Karthik and Ko, Steven Y.},title={SLAM Adversarial Lab: An Extensible Framework for Visual SLAM Robustness Evaluation under Adverse Conditions},booktitle={2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},year={2026},month=sep,issue_date={Sep 2026},publisher={IEEE},url={https://2026.ieee-iros.org/program/contributed_talks/#f282f3:4564},note={Accepted for publication},}
IROS
TurboMap: GPU-Accelerated Local Mapping for Visual SLAM
@inproceedings{turbomap,author={Hosseininejad, Parsa and Khabiri, Kimia and Gopinath, Shishir and Mohammadhashemi, Soudabeh and Dantu, Karthik and Ko, Steven Y.},title={TurboMap: GPU-Accelerated Local Mapping for Visual SLAM},booktitle={2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},year={2026},month=sep,issue_date={Sep 2026},publisher={IEEE},url={https://2026.ieee-iros.org/program/contributed_talks/#8fc08d:4372},note={Accepted for publication},}
ISRR
CART: Context-Aware Terrain Adaptation using Temporal Sequence Selection for Legged Robots
@inproceedings{cart,author={Singh, Kartikeya and Kim, Youngjin and Turkar, Yash and Dantu, Karthik},title={CART: Context-Aware Terrain Adaptation using Temporal Sequence Selection for Legged Robots},booktitle={International Symposium of Robotics Research (ISRR)},year={2026},note={Accepted for publication},url={https://arxiv.org/abs/2604.14344},}
CRV
Empir3D: A Framework for Multi-Dimensional Point Cloud Assessment
@inproceedings{CRVI26a,author={Turkar, Yash and Meshram, Pranay and Aluckal, Christo and Adhivarahan, Charuvahan and Dantu, Karthik},title={Empir3D: A Framework for Multi-Dimensional Point Cloud Assessment},booktitle={Proceedings of the 23rd Conference on Robots and Vision},year={2026},publisher={PubPub},doi={10.21428/d82e957c.900da59a},url={https://crv.pubpub.org/pub/dlf0gaqg},}
CRV
Enhancing Visual Odometry with Reliable Pixel Masking
@inproceedings{CRVI26b,author={Turkar, Yash and Chase, Jr, Timothy and Aluckal, Christo and Dantu, Karthik},title={Enhancing Visual Odometry with Reliable Pixel Masking},booktitle={Proceedings of the 23rd Conference on Robots and Vision},year={2026},publisher={PubPub},doi={10.21428/d82e957c.519b98ec},url={https://crv.pubpub.org/pub/fv2mnwrd},}
ICRA
Graphite: A GPU-Accelerated Mixed-Precision Graph Optimization Framework
@inproceedings{graphite,author={Gopinath, Shishir and Dantu, Karthik and Ko, Steven Y.},title={Graphite: A GPU-Accelerated Mixed-Precision Graph Optimization Framework},booktitle={2026 IEEE International Conference on Robotics and Automation (ICRA)},year={2026},publisher={IEEE},url={https://ras.papercept.net/conferences/conferences/ICRA26/program/ICRA26_ContentListWeb_5.html#thi1i_335},}
RSS
Learning When to Jump for Off-road Navigation
Zhipeng Zhao, Taimeng Fu, Shaoshu Su, Qiwei Du, Ehsan Esfahani, Karthik K. Dantu, Souma Chowdhury, and Chen Wang
@inproceedings{RSSC26,author={Zhao, Zhipeng and Fu, Taimeng and Su, Shaoshu and Du, Qiwei and Esfahani, Ehsan and Dantu, Karthik K. and Chowdhury, Souma and Wang, Chen},title={Learning When to Jump for Off-road Navigation},booktitle={Robotics: Science and Systems XXII},year={2026},publisher={Robotics: Science and Systems Foundation},doi={10.15607/rss.2026.xxii.066},url={https://www.roboticsproceedings.org/rss22/p066.html},}
WACV
QAL: A Loss for Recall–Precision Balance in 3D Reconstruction
@inproceedings{WACV26,author={Meshram, Pranay and Turkar, Yash and Singh, Kartikeya and Masilamani, Praveen Raj and Adhivarahan, Charuvahan and Dantu, Karthik},title={QAL: A Loss for Recall–Precision Balance in 3D Reconstruction},booktitle={2026 IEEE/CVF Winter Conference on Applications of Computer Vision (WACV)},year={2026},pages={7965--7974},publisher={IEEE},doi={10.1109/wacv61042.2026.00769},url={https://ieeexplore.ieee.org/document/11492244/},}
CLAWAR
Task-Conditioned Uncertainty Costmaps for Legged Locomotion
@inproceedings{costmaps,author={Singh, Kartikeya and Aluckal, Christo and Orsolino, Romeo and Dantu, Karthik},title={Task-Conditioned Uncertainty Costmaps for Legged Locomotion},booktitle={29th International Conference on Climbing and Walking Robots and the Support Technologies for Mobile Machines (CLAWAR)},year={2026},note={Paper 10},url={https://arxiv.org/abs/2605.00261},}
@inproceedings{tips,author={Duong, Long and Adhivarahan, Charuvahan and Ayyalasomayajula, Roshan and Dantu, Karthik},title={TIPS: Thermal Image based Plastics Sorting},booktitle={Proceedings of the 24th Annual International Conference on Mobile Systems, Applications and Services},year={2026},pages={247--260},publisher={ACM},doi={10.1145/3745756.3809202},url={https://dl.acm.org/doi/10.1145/3745756.3809202},}
ISER
Active Illumination Control in Low-Light Environments using NightHawk
@inproceedings{nighthawk,author={Turkar, Yash and Kim, Youngjin and Dantu, Karthik},title={Active Illumination Control in Low-Light Environments using NightHawk},booktitle={19th International Symposium on Experimental Robotics (ISER)},year={2025},url={https://arxiv.org/abs/2506.06394},}
CASE
Automated Generation of Diverse Courses of Actions for Multi-Agent Operations using Binary Optimization and Graph Learning
Prithvi Poddar, Ehsan Tarkesh Esfahani, Karthik Dantu, and Souma Chowdhury
In 2025 IEEE 21st International Conference on Automation Science and Engineering (CASE), 2025
@inproceedings{CASE25,author={Poddar, Prithvi and Esfahani, Ehsan Tarkesh and Dantu, Karthik and Chowdhury, Souma},title={Automated Generation of Diverse Courses of Actions for Multi-Agent Operations using Binary Optimization and Graph Learning},booktitle={2025 IEEE 21st International Conference on Automation Science and Engineering (CASE)},year={2025},pages={2901--2908},publisher={IEEE},doi={10.1109/case58245.2025.11163864},url={https://ieeexplore.ieee.org/document/11163864/},}
ICMLA
CLIPS: Continual Learning Infrastructure for Plastics Sorting
@inproceedings{IMLA25,author={Mehta, Shivm and Maheshkar, Vaishali and Adhivarahan, Charuvahan and Dantu, Karthik},title={CLIPS: Continual Learning Infrastructure for Plastics Sorting},booktitle={2025 International Conference on Machine Learning and Applications (ICMLA)},year={2025},pages={1197--1204},publisher={IEEE},doi={10.1109/icmla66185.2025.00183},url={https://ieeexplore.ieee.org/document/11471507/},}
IROS
FastTrack: GPU-Accelerated Tracking for Visual SLAM
@inproceedings{fasttrack,author={Khabiri, Kimia and Hosseininejad, Parsa and Gopinath, Shishir and Dantu, Karthik and Ko, Steven Y.},title={FastTrack: GPU-Accelerated Tracking for Visual SLAM},booktitle={2025 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},year={2025},pages={15165--15172},publisher={IEEE},doi={10.1109/iros60139.2025.11247316},url={https://ieeexplore.ieee.org/document/11247316/},}
EMBC
Hybrid Human Model for Time of Hike Prediction
Kristian Dalland, Chen Wang, Karthik Dantu, Souma Chowdhury, and Ehsan T Esfahani
In 2025 47th Annual International Conference of the IEEE Engineering in Medicine and Biology Society (EMBC), 2025
@inproceedings{EMBC25,author={Dalland, Kristian and Wang, Chen and Dantu, Karthik and Chowdhury, Souma and Esfahani, Ehsan T},title={Hybrid Human Model for Time of Hike Prediction},booktitle={2025 47th Annual International Conference of the IEEE Engineering in Medicine and Biology Society (EMBC)},year={2025},pages={1--6},publisher={IEEE},doi={10.1109/embc58623.2025.11253206},url={https://ieeexplore.ieee.org/document/11253206/},}
SIMPAR
TERA: A Simulation Environment for Terrain Excavation Robot Autonomy
@inproceedings{tera,author={Aluckal, Christo and Kumar Lal, Roopesh Vinodh and Courtney, Sean and Turkar, Yash and Dighe, Yashom and Kim, Youngjin and Gemerek, Jake and Dantu, Karthik},title={TERA: A Simulation Environment for Terrain Excavation Robot Autonomy},booktitle={2025 IEEE International Conference on Simulation, Modeling, and Programming for Autonomous Robots (SIMPAR)},year={2025},pages={1--6},publisher={IEEE},doi={10.1109/simpar62925.2025.10979147},url={https://ieeexplore.ieee.org/document/10979147/},}
REMADE
Detailed Evaluation of Modern Machine Learning Approaches for Optic Plastics Sorting
@inproceedings{REMA26,author={Maheshkar, Vaishali and Ramakrishnan, Aadarsh Anantha and Adhivarahan, Charuvahan and Dantu, Karthik},title={Detailed Evaluation of Modern Machine Learning Approaches for Optic Plastics Sorting},booktitle={Proceedings of the 2024 REMADE® Circular Economy Technology Summit \& Conference},year={2024},publisher={REMADE Institute},doi={10.65569/xtzt3948},url={https://remadeinstitute.org/academic-papers/detailed-evaluation-of-modern-machine-learning-approaches-for-optic-plastics-sorting/},}
@inproceedings{XRSL24,author={Turkar, Yash and Aluckal, Christo and Adhivarahan, Charuvahan and Sebastiani, Alessandro and Dantu, Karthik},title={A View-Planning Approach to 3D Reconstruction},booktitle={Extended Reality: International Conference, XR Salento 2024, Proceedings, Part III},year={2024},volume={15029},series={Lecture Notes in Computer Science},pages={340--350},publisher={Springer Nature Switzerland},doi={10.1007/978-3-031-71710-9_27},url={https://link.springer.com/10.1007/978-3-031-71710-9_27},}
IJCB
DIOR: Dataset for Indoor-Outdoor Reidentification Long Range 3D/2D Skeleton Gait Collection Pipeline, Semi-Automated Gait Keypoint Labeling and Baseline Evaluation Methods
@inproceedings{IJCB24,author={Chen, Yuyang and Masilamani, Praveen Raj and Jawade, Bhavin and Setlur, Srirangaraj and Dantu, Karthik},title={DIOR: Dataset for Indoor-Outdoor Reidentification Long Range 3D/2D Skeleton Gait Collection Pipeline, Semi-Automated Gait Keypoint Labeling and Baseline Evaluation Methods},booktitle={2024 IEEE International Joint Conference on Biometrics (IJCB)},year={2024},pages={1--9},publisher={IEEE},doi={10.1109/ijcb62174.2024.10744452},url={https://ieeexplore.ieee.org/document/10744452/},}
IGARSS
Enhancing Archaeological Surveys with InSAR Imagery and UAV-Based GPR
@inproceedings{IGRS24,author={Turkar, Yash and De, Shaunak and Adhivarahan, Charuvahan and Mottola, Luca and Sebastiani, Alessandro and Castelletti, Davide and Dantu, Karthik},title={Enhancing Archaeological Surveys with InSAR Imagery and UAV-Based GPR},booktitle={IGARSS 2024 - 2024 IEEE International Geoscience and Remote Sensing Symposium},year={2024},pages={11454--11456},publisher={IEEE},doi={10.1109/igarss53475.2024.10640645},url={https://ieeexplore.ieee.org/document/10640645/},}
ICRA
JacobiGPU: GPU-Accelerated Numerical Differentiation for Loop Closure in Visual SLAM
@inproceedings{jacobigpu,author={Kumar, Dhruv and Gopinath, Shishir and Dantu, Karthik and Ko, Steven Y.},title={JacobiGPU: GPU-Accelerated Numerical Differentiation for Loop Closure in Visual SLAM},booktitle={2024 IEEE International Conference on Robotics and Automation (ICRA)},year={2024},pages={1687--1693},publisher={IEEE},doi={10.1109/icra57147.2024.10611512},url={https://ieeexplore.ieee.org/document/10611512/},}
ICRA
L-DYNO: Framework to Learn Consistent Visual Features Using Robot’s Motion
@inproceedings{ICRA24b,author={Singh, Kartikeya and Adhivarahan, Charuvahan and Dantu, Karthik},title={L-DYNO: Framework to Learn Consistent Visual Features Using Robot’s Motion},booktitle={2024 IEEE International Conference on Robotics and Automation (ICRA)},year={2024},pages={17522--17528},publisher={IEEE},doi={10.1109/icra57147.2024.10611097},url={https://ieeexplore.ieee.org/document/10611097/},}
ECCV
MARs: Multi-view Attention Regularizations for Patch-Based Feature Recognition of Space Terrain
@inproceedings{mars,author={Chase, Jr, Timothy and Dantu, Karthik},title={MARs: Multi-view Attention Regularizations for Patch-Based Feature Recognition of Space Terrain},booktitle={Computer Vision – ECCV 2024, Part LXIV},year={2024},volume={15122},series={Lecture Notes in Computer Science},pages={219--239},publisher={Springer Nature Switzerland},doi={10.1007/978-3-031-73039-9_13},url={https://link.springer.com/10.1007/978-3-031-73039-9_13},}
AeroConf
Profiling Vision-based Deep Learning Architectures on NASA SpaceCube Platforms
Timothy Chase, Justin Goodwill, Karthik Dantu, and Christopher Wilson
@inproceedings{spacecube,author={Chase, Timothy and Goodwill, Justin and Dantu, Karthik and Wilson, Christopher},title={Profiling Vision-based Deep Learning Architectures on NASA SpaceCube Platforms},booktitle={2024 IEEE Aerospace Conference},year={2024},pages={1--16},publisher={IEEE},doi={10.1109/aero58975.2024.10521096},url={https://ieeexplore.ieee.org/document/10521096/},}
AeroConf
Unsupervised Surface-to-Orbit View Generation of Planetary Terrain
Timothy Chase, Sannihith Kilaru, Shivendra Srinivas, and Karthik Dantu
@inproceedings{AERO24b,author={Chase, Timothy and Kilaru, Sannihith and Srinivas, Shivendra and Dantu, Karthik},title={Unsupervised Surface-to-Orbit View Generation of Planetary Terrain},booktitle={2024 IEEE Aerospace Conference},year={2024},pages={1--14},publisher={IEEE},doi={10.1109/aero58975.2024.10521336},url={https://ieeexplore.ieee.org/document/10521336/},}
REMADE
Valorization of Plastic Waste via Advanced Separation and Processing
Paschalis Alexandridis, Karthik Dantu, Christian Ferger, Ali Ghasemi, Gabrielle Kerr, Vaishali Maheshkar, Javid Rzayev, Nicholas Stavinski, Thomas Thundat, Marina Tsianou, Luis Velarde, and Yaoli Zhao
In Technology Innovation for the Circular Economy: Recycling, Remanufacturing, Design, System Analysis and Logistics (2023 REMADE Conference Proceedings), 2024
@inproceedings{REMA24,author={Alexandridis, Paschalis and Dantu, Karthik and Ferger, Christian and Ghasemi, Ali and Kerr, Gabrielle and Maheshkar, Vaishali and Rzayev, Javid and Stavinski, Nicholas and Thundat, Thomas and Tsianou, Marina and Velarde, Luis and Zhao, Yaoli},title={Valorization of Plastic Waste via Advanced Separation and Processing},booktitle={Technology Innovation for the Circular Economy: Recycling, Remanufacturing, Design, System Analysis and Logistics (2023 REMADE Conference Proceedings)},year={2024},pages={495--506},publisher={Wiley},doi={10.1002/9781394214297.ch38},url={https://onlinelibrary.wiley.com/doi/10.1002/9781394214297.ch38},editor={Nasr, Nabil},}
MobiSys
VRF: Vehicle Road-side Point Cloud Fusion
Kaleem Nawaz Khan, Ali Khalid, Yash Turkar, Karthik Dantu, and Fawad Ahmad
In Proceedings of the 22nd Annual International Conference on Mobile Systems, Applications and Services, 2024
@inproceedings{MOBS24,author={Khan, Kaleem Nawaz and Khalid, Ali and Turkar, Yash and Dantu, Karthik and Ahmad, Fawad},title={VRF: Vehicle Road-side Point Cloud Fusion},booktitle={Proceedings of the 22nd Annual International Conference on Mobile Systems, Applications and Services},year={2024},pages={547--560},publisher={ACM},doi={10.1145/3643832.3661874},url={https://dl.acm.org/doi/10.1145/3643832.3661874},}
IJCAI
AI-Driven Sign Language Interpretation for Nigerian Children at Home
Ifeoma Nwogu, Roshan Peiris, Karthik Dantu, Ruchi Gamta, and Emma Asonye
In Proceedings of the Thirty-Second International Joint Conference on Artificial Intelligence, 2023
@inproceedings{IJCA23,author={Nwogu, Ifeoma and Peiris, Roshan and Dantu, Karthik and Gamta, Ruchi and Asonye, Emma},title={AI-Driven Sign Language Interpretation for Nigerian Children at Home},booktitle={Proceedings of the Thirty-Second International Joint Conference on Artificial Intelligence},year={2023},pages={6395--6404},publisher={International Joint Conferences on Artificial Intelligence Organization},doi={10.24963/ijcai.2023/710},url={https://www.ijcai.org/proceedings/2023/710},}
MobiCom
Anemoi: A Low-cost Sensorless Indoor Drone System for Automatic Mapping of 3D Airflow Fields
Stephen Xia, Minghui Zhao, Charuvahan Adhivarahan, Kaiyuan Hou, Yuyang Chen, Jingping Nie, Eugene Wu, Karthik Dantu, and Xiaofan Jiang
In Proceedings of the 29th Annual International Conference on Mobile Computing and Networking, 2023
@inproceedings{MCOM23,author={Xia, Stephen and Zhao, Minghui and Adhivarahan, Charuvahan and Hou, Kaiyuan and Chen, Yuyang and Nie, Jingping and Wu, Eugene and Dantu, Karthik and Jiang, Xiaofan},title={Anemoi: A Low-cost Sensorless Indoor Drone System for Automatic Mapping of 3D Airflow Fields},booktitle={Proceedings of the 29th Annual International Conference on Mobile Computing and Networking},year={2023},article_number={77},pages={1--16},publisher={ACM},doi={10.1145/3570361.3613292},url={https://dl.acm.org/doi/10.1145/3570361.3613292},}
IROS
Fast Decision Support for Air Traffic Management at Urban Air Mobility Vertiports Using Graph Learning
Prajit KrisshnaKumar, Jhoel Witter, Steve Paul, Hanvit Cho, Karthik Dantu, and Souma Chowdhury
In 2023 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2023
@inproceedings{IROS23a,author={KrisshnaKumar, Prajit and Witter, Jhoel and Paul, Steve and Cho, Hanvit and Dantu, Karthik and Chowdhury, Souma},title={Fast Decision Support for Air Traffic Management at Urban Air Mobility Vertiports Using Graph Learning},booktitle={2023 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},year={2023},pages={1580--1585},publisher={IEEE},doi={10.1109/iros55552.2023.10341398},url={https://ieeexplore.ieee.org/document/10341398/},}
SciTech
Graph Learning based Decision Support for Multi-Aircraft Take-Off and Landing at Urban Air Mobility Vertiports
Prajit K. Kumar, Jhoel Witter, Steve Paul, Karthik Dantu, and Souma Chowdhury
@inproceedings{SCIT23,author={Kumar, Prajit K. and Witter, Jhoel and Paul, Steve and Dantu, Karthik and Chowdhury, Souma},title={Graph Learning based Decision Support for Multi-Aircraft Take-Off and Landing at Urban Air Mobility Vertiports},booktitle={AIAA SCITECH 2023 Forum},year={2023},note={AIAA Paper 2023-1848},publisher={American Institute of Aeronautics and Astronautics},doi={10.2514/6.2023-1848},url={https://arc.aiaa.org/doi/10.2514/6.2023-1848},}
ICRA
Improving the Performance of Local Bundle Adjustment for Visual-Inertial SLAM with Efficient Use of GPU Resources
@inproceedings{localba,author={Gopinath, Shishir and Dantu, Karthik and Ko, Steven Y.},title={Improving the Performance of Local Bundle Adjustment for Visual-Inertial SLAM with Efficient Use of GPU Resources},booktitle={2023 IEEE International Conference on Robotics and Automation (ICRA)},year={2023},pages={6239--6245},publisher={IEEE},doi={10.1109/icra48891.2023.10160499},url={https://ieeexplore.ieee.org/document/10160499/},}
IROS
Kinematics-Only Differential Flatness Based Trajectory Tracking for Autonomous Racing
@inproceedings{IROS23b,author={Dighe, Yashom and Kim, Youngjin and Rajguru, Smit and Turkar, Yash and Singh, Tarunraj and Dantu, Karthik},title={Kinematics-Only Differential Flatness Based Trajectory Tracking for Autonomous Racing},booktitle={2023 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},year={2023},pages={1629--1636},publisher={IEEE},doi={10.1109/iros55552.2023.10341603},url={https://ieeexplore.ieee.org/document/10341603/},}
CVPR
PyPose: A Library for Robot Learning with Physics-based Optimization
Chen Wang, Dasong Gao, Kuan Xu, Junyi Geng, Yaoyu Hu, Yuheng Qiu, Bowen Li, Fan Yang, Brady Moon, Abhinav Pandey, Aryan, Jiahe Xu, Tianhao Wu, Haonan He, Daning Huang, Zhongqiang Ren, Shibo Zhao, Taimeng Fu, Pranay Reddy, Xiao Lin, Wenshan Wang, Jingnan Shi, Rajat Talak, Kun Cao, Yi Du, Han Wang, Huai Yu, Shanzhao Wang, Siyu Chen, Ananth Kashyap, Rohan Bandaru, Karthik Dantu, Jiajun Wu, Lihua Xie, Luca Carlone, Marco Hutter, and Sebastian Scherer
In 2023 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR)· Open access , 2023
@inproceedings{CVPR23,author={Wang, Chen and Gao, Dasong and Xu, Kuan and Geng, Junyi and Hu, Yaoyu and Qiu, Yuheng and Li, Bowen and Yang, Fan and Moon, Brady and Pandey, Abhinav and {Aryan} and Xu, Jiahe and Wu, Tianhao and He, Haonan and Huang, Daning and Ren, Zhongqiang and Zhao, Shibo and Fu, Taimeng and Reddy, Pranay and Lin, Xiao and Wang, Wenshan and Shi, Jingnan and Talak, Rajat and Cao, Kun and Du, Yi and Wang, Han and Yu, Huai and Wang, Shanzhao and Chen, Siyu and Kashyap, Ananth and Bandaru, Rohan and Dantu, Karthik and Wu, Jiajun and Xie, Lihua and Carlone, Luca and Hutter, Marco and Scherer, Sebastian},title={PyPose: A Library for Robot Learning with Physics-based Optimization},booktitle={2023 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR)},year={2023},pages={22024--22034},publisher={IEEE},doi={10.1109/cvpr52729.2023.02109},url={https://ieeexplore.ieee.org/document/10204505/},}
HotMobile
A quantitative analysis of system bottlenecks in visual SLAM
@inproceedings{bottlenecks,author={Semenova, Sofiya and Ko, Steven Y. and Liu, Yu David and Ziarek, Lukasz and Dantu, Karthik},title={A quantitative analysis of system bottlenecks in visual SLAM},booktitle={Proceedings of the 23rd Annual International Workshop on Mobile Computing Systems and Applications},year={2022},pages={74--80},publisher={ACM},doi={10.1145/3508396.3512882},url={https://dl.acm.org/doi/10.1145/3508396.3512882},}
SciTech
Efficient Feature Matching and Mapping for Terrain Relative Navigation Using Hypothesis Gating
Chris Gnam, Timothy B. Chase, Karthik Dantu, and John L. Crassidis
@inproceedings{gating,author={Gnam, Chris and Chase, Timothy B. and Dantu, Karthik and Crassidis, John L.},title={Efficient Feature Matching and Mapping for Terrain Relative Navigation Using Hypothesis Gating},booktitle={AIAA SCITECH 2022 Forum},year={2022},note={AIAA Paper 2022-2513},publisher={American Institute of Aeronautics and Astronautics},doi={10.2514/6.2022-2513},url={https://arc.aiaa.org/doi/10.2514/6.2022-2513},}
MASS
PRE-SLAM: Persistence Reasoning in Edge-assisted Visual SLAM
@inproceedings{preslam,author={Chase, Timothy and Ben Ali, Ali J. and Ko, Steven Y. and Dantu, Karthik},title={PRE-SLAM: Persistence Reasoning in Edge-assisted Visual SLAM},booktitle={2022 IEEE 19th International Conference on Mobile Ad Hoc and Smart Systems (MASS)},year={2022},pages={458--466},publisher={IEEE},doi={10.1109/mass56207.2022.00071},url={https://ieeexplore.ieee.org/document/9973604/},}
AAS
You Only Crash Once: Improved Object Detection for Real-Time, Sim-to-Real Hazardous Terrain Detection and Classification for Autonomous Planetary Landings
Timothy Chase, Chris Gnam, John Crassidis, and Karthik Dantu
In AAS/AIAA Astrodynamics Specialist Conference , 2022
@inproceedings{crash,author={Chase, Jr, Timothy and Gnam, Chris and Crassidis, John and Dantu, Karthik},title={You Only Crash Once: Improved Object Detection for Real-Time, Sim-to-Real Hazardous Terrain Detection and Classification for Autonomous Planetary Landings},booktitle={AAS/AIAA Astrodynamics Specialist Conference},year={2022},address={Charlotte, North Carolina},note={AAS Paper 22-638},url={https://space-flight.org/docs/2022_summer/ASC22_FullProgram_Compiled.pdf},}
IROS
JCopter: Reliable UAV Software Through Managed Languages
Adam Czerniejewski, John Henry Burns, Farshad Ghanei, Karthik Dantu, Yu David Liu, and Lukasz Ziarek
In 2021 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2021
@inproceedings{IROS21,author={Czerniejewski, Adam and Burns, John Henry and Ghanei, Farshad and Dantu, Karthik and Liu, Yu David and Ziarek, Lukasz},title={JCopter: Reliable UAV Software Through Managed Languages},booktitle={2021 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},year={2021},pages={4282--4289},doi={10.1109/iros51168.2021.9636617},url={https://ieeexplore.ieee.org/document/9636617/},}
MRS
Learning Robot Swarm Tactics over Complex Adversarial Environments
Amir Behjat, Hemanth Manjunatha, Prajit Krisshna Kumar, Apurv Jani, Leighton Collins, Payam Ghassemi, Joseph Distefano, David Doermann, Karthik Dantu, Ehsan Esfahani, and Souma Chowdhury
In 2021 International Symposium on Multi-Robot and Multi-Agent Systems (MRS), 2021
@inproceedings{MRSA21,author={Behjat, Amir and Manjunatha, Hemanth and Kumar, Prajit Krisshna and Jani, Apurv and Collins, Leighton and Ghassemi, Payam and Distefano, Joseph and Doermann, David and Dantu, Karthik and Esfahani, Ehsan and Chowdhury, Souma},title={Learning Robot Swarm Tactics over Complex Adversarial Environments},booktitle={2021 International Symposium on Multi-Robot and Multi-Agent Systems (MRS)},year={2021},pages={83--91},doi={10.1109/mrs50823.2021.9620707},url={https://ieeexplore.ieee.org/document/9620707/},}
Understanding Bounding Functions in Safety-Critical UAV Software
Xiaozhou Liang, John Henry Burns, Joseph Sanchez, Karthik Dantu, Lukasz Ziarek, and Yu David Liu
In Proceedings of the 43rd International Conference on Software Engineering, Virtual, 2021
@inproceedings{boundedvariables,author={Liang, Xiaozhou and Burns, John Henry and Sanchez, Joseph and Dantu, Karthik and Ziarek, Lukasz and Liu, Yu David},title={Understanding Bounding Functions in Safety-Critical UAV Software},year={2021},publisher={IEEE/ACM},url={https://conf.researchr.org/details/icse-2021/icse-2021-papers/30/Understanding-Bounding-Functions-in-Safety-Critical-UAV-Software},booktitle={Proceedings of the 43rd International Conference on Software Engineering},pages={},numpages={},keywords={},location={Virtual},series={ICSE '21},}
SMC
Using Physiological Information to Classify Task Difficulty in Human-Swarm Interaction
Joseph P. Distefano, Hemanth Manjunatha, Souma Chowdhury, Karthik Dantu, David Doermann, and Ehsan T. Esfahani
In 2021 IEEE International Conference on Systems, Man, and Cybernetics (SMC), 2021
@inproceedings{SMCC21,author={Distefano, Joseph P. and Manjunatha, Hemanth and Chowdhury, Souma and Dantu, Karthik and Doermann, David and Esfahani, Ehsan T.},title={Using Physiological Information to Classify Task Difficulty in Human-Swarm Interaction},booktitle={2021 IEEE International Conference on Systems, Man, and Cybernetics (SMC)},year={2021},pages={1198--1203},doi={10.1109/smc52423.2021.9658653},url={https://ieeexplore.ieee.org/document/9658653/},}
MobiSys
Edge-SLAM: Edge-Assisted Visual Simultaneous Localization and Mapping
@inproceedings{edgeslam2020,author={Ben Ali, Ali J. and Hashemifar, Zakieh Sadat and Dantu, Karthik},title={Edge-SLAM: Edge-Assisted Visual Simultaneous Localization and Mapping},year={2020},isbn={9781450379540},publisher={Association for Computing Machinery},address={New York, NY, USA},url={https://doi.org/10.1145/3386901.3389033},doi={10.1145/3386901.3389033},booktitle={Proceedings of the 18th International Conference on Mobile Systems, Applications, and Services},pages={325–337},numpages={13},keywords={mobile systems, mapping, visual simultaneous localization and mapping, split architecture, localization, edge computing},location={Toronto, Ontario, Canada},series={MobiSys '20},}
@inproceedings{Ghanei:2018:acbba,author={Rantanen, Matthew and Modares, Jalil and Mastronarde, Nicholas and Ghanei, Farshad and Dantu, Karthik},journal={Sensor Array and Multichannel Signal Processing Workshop (SAM)},title={Performance of the Asynchronous Consensus Based Bundle Algorithm in Lossy Network Environments},year={2018},volume={},number={},pages={311-315},keywords={Task analysis;Resource management;Drones;Signal processing algorithms;Planning;Robot sensing systems;Unmanned aerial vehicles (UAVs);wireless networking;decentralized task allocation},doi={10.1109/SAM.2018.8448984},issn={2151-870X},month=jul,}
UB-ANC planner: Energy efficient coverage path planning with multiple drones
J. Modares, F. Ghanei, N. Mastronarde, and K. Dantu
@inproceedings{Ghanei:2016:ORA:2934583.2934639,author={Ghanei, Farshad and Tipnis, Pranav and Marcus, Kyle and Dantu, Karthik and Ko, Steve and Ziarek, Lukasz},title={OS-based Resource Accounting for Asynchronous Resource Use in Mobile Systems},journal={International Symposium on Low Power Electronics and Design (ISLPED)},series={ISLPED '16},year={2016},isbn={978-1-4503-4185-1},location={San Francisco Airport, CA, USA},pages={296--301},numpages={6},url={http://doi.acm.org/10.1145/2934583.2934639},doi={10.1145/2934583.2934639},acmid={2934639},publisher={ACM},address={New York, NY, USA},keywords={Embedded Systems, Operating Systems, Power Management, Resource Management},}